CreatorMotion · Title Scene Takeover


 +7

@mendonca_rlBuild walkthroughs
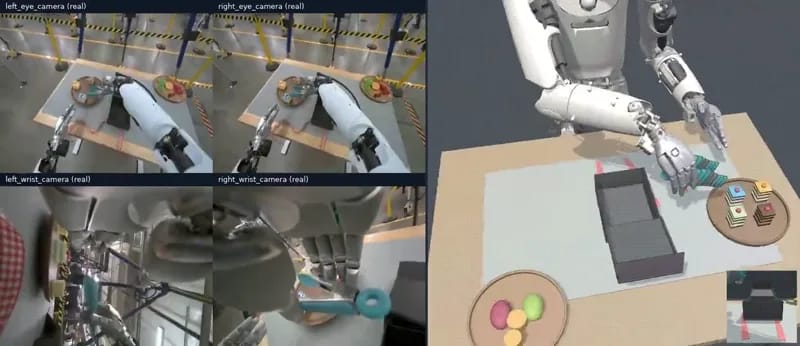
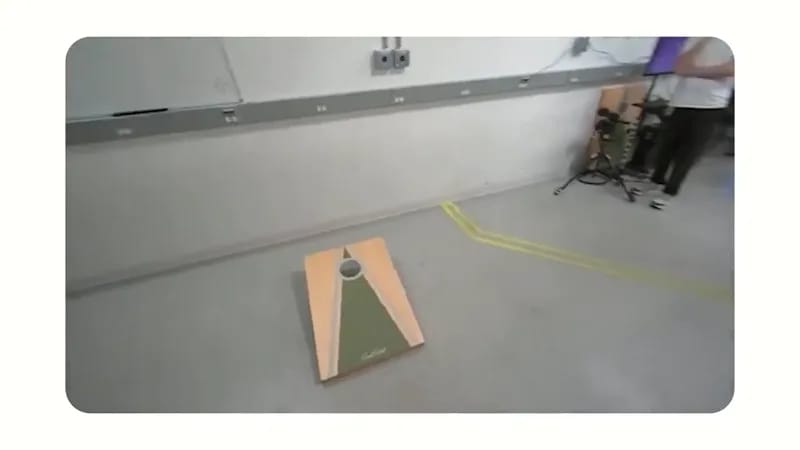
Argon can also plan effectively in world models! Here it went through an iterated loop of 1) writing out plans for how to achieve a goal 2) using an omni world model to simulate consequences of actions 3) reflect on produced rollouts to modify the plan. This is the resulting video plan. More details in our blog - https://developers.googleblog.com/gemini-4-argon-for-robotics/
 Build walkthroughsNew1:43
 Build walkthroughsNew0:51